top of page
Latest News


Mobile Robot: A Buyer’s Guide to Research Workflows
Explore mobile robot requirements, mobility options, sensing, data workflows, and validation steps to scope a platform for physical AI research.
Marc Dostie
5 days ago


Tactile Sensing and Control of Robotic Manipulation: A Practical Guide
Explore tactile sensing and control of robotic manipulation, from contact detection and force regulation to data capture, evaluation, and sim-to-real tests.
Marc Dostie
6 days ago


Robot Servo Controller: How to Choose and Integrate Motion Control Hardware
Learn how to choose a robot servo controller by comparing communication, feedback, torque, timing, safety, and software needs for your robotics project.
Marc Dostie
Oct 21


Open X Embodiment: Dataset Guide for Robot Learning
Open X Embodiment explained: explore its scale, robot diversity, research value, data formats, limitations, and path to real-robot evaluation.
Marc Dostie
Oct 20

Built to Be Hacked: Why Research Robots Have to Stay Open
A research robot has to support experiments its designers haven’t thought of yet. Matt Trossen explains why we build our hardware to be changed.
Nupur Patra
Oct 19


Robotic End of Arm Tooling: A Practical Guide
Choose robotic end of arm tooling by task, payload, reach, interfaces, and repeatability with this practical guide for research and automation teams.
Marc Dostie
Oct 19


Robot Data Collection Platform: Hardware and Scale
Evaluate a robot data collection platform across hardware, teleoperation, capture, metadata, storage, quality checks, and scale before you commit.
Marc Dostie
Oct 16

How a University Lab Teaches a Robot Arm Pick and Place with Physical AI and the Trossen Solo AI Kit
A university research lab is using the Trossen Solo AI kit to teach a robot arm to pick up any manufacturing part, in any orientation, and place it in the right bin from a simple prompt. Ali Beydoun, a researcher focused on physical AI, documented the full journey in a detailed post: Bringing a Robot Arm to Life with Trossen Robotics AI. He covers how he chose an arm, set it up, collected training data and fine-tuned a vision-language-action model. He also notes that his post
Nupur Patra
Oct 15


Behavior Cloning Robotics: From Human Demonstrations to Robot Policies
Explore behavior cloning robotics, from recording clean teleoperation demonstrations to validating learned policies and deploying them on real hardware.
Marc Dostie
Oct 14


Machine Learning Robot Arm Platforms: A Comparison
Compare machine learning robot arm platforms across hardware, cameras, teleoperation, data, compute, inference, documentation, and scale for physical AI.
Marc Dostie
Oct 13


From Handheld Demos to Searchable Training Data: Annotating TRumi Episodes with DecisionFacts and Foxglove
Collecting handheld demonstrations is only half the job. The other half is robotics data annotation: turning hours of raw episodes into multimodal training data a team can actually search, review, and train on. Our partners at DecisionFacts just showed what that second half can look like. They built a pipeline that takes episodes captured on TRumi, Trossen Robotics' handheld data collection device, and turns them into annotated, synchronized files that open directly in Foxglo
Nupur Patra
Oct 12


Bimanual Robot Arm Systems: Evaluation Criteria for AI Research
Evaluate a bimanual robot arm for research with a practical framework for synchronization, reach, calibration, sensing, software, and support.
Marc Dostie
Oct 8


Physical AI Startup Hardware Strategy: From Prototype to Repeatable Robot Data
Explore physical ai startup decisions for hardware, software, data workflows, and support, from first prototype through a repeatable pilot.
Marc Dostie
Oct 6


Robot Arm ROS: Integration Guide for Research Teams
Learn how to integrate a robot arm ROS workflow for research, then build a repeatable path from motion and sensing to safe, synchronized data capture.
Marc Dostie
Oct 5
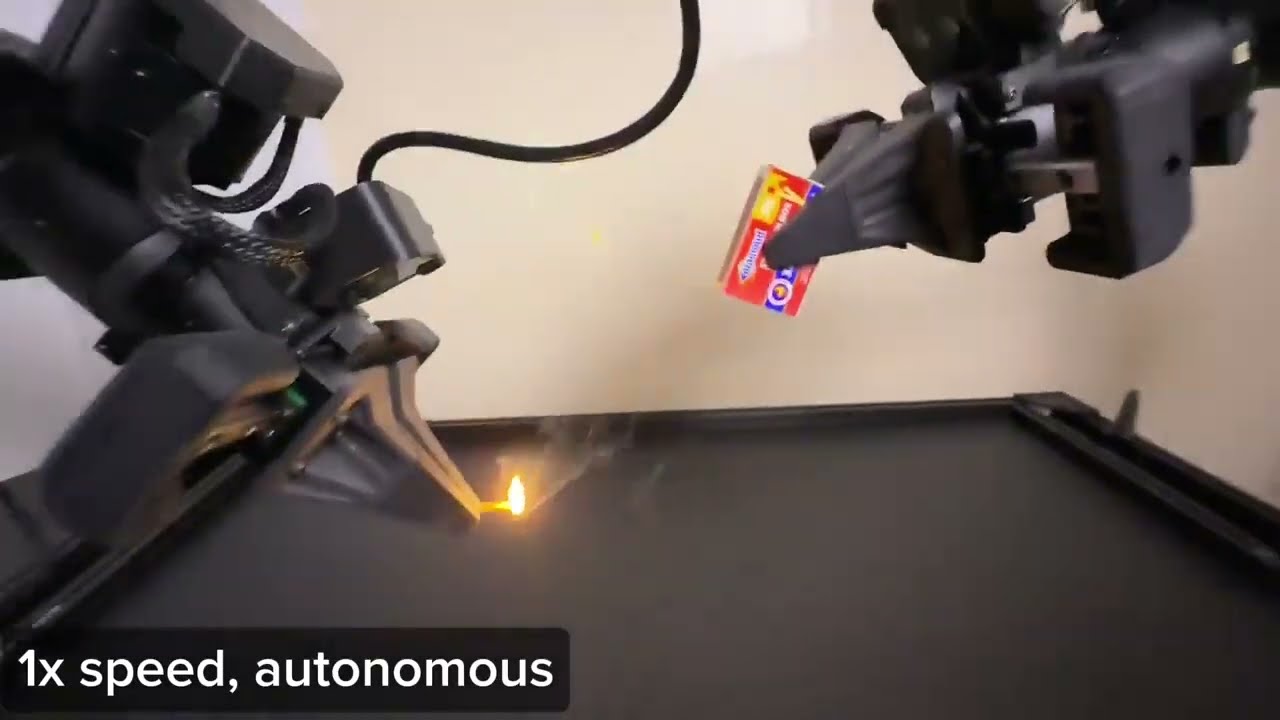
How Two Trossen Arms Learned to Strike a Match
Two Trossen arms struck a match completely on their own. The demo comes from NAC, research by Ahad Jawaid and Yu Xiang at UT Dallas heading to CoRL 2026, which borrows audio compression tricks to help robots learn precise, coordinated tasks.
Nupur Patra
Sep 29


Robotics Training Data: A Practical Capture Guide
Learn how to capture robotics training data with better task design, teleoperation, synchronized sensors, episode metadata, quality control, and evaluation.
Marc Dostie
Sep 29


Bimanual Manipulation: A Research Workflow Guide
Learn how bimanual manipulation teams coordinate arms, sensing, teleoperation, calibration, data capture, and evaluation for repeatable robot-learning research.
Marc Dostie
Sep 28


WidowX Robot Arm: Specs and Research Fit
Explore the WidowX robot arm's specifications, sensing, configurations, and software, then assess its fit for university, startup, and enterprise R&D workflows.
Marc Dostie
Sep 25


Mobile ALOHA Robot: A Field Research Guide
A mobile aloha robot field guide for research teams, covering bimanual workflows, teleoperation, repeatable demonstrations, data capture, and model evaluation.
Marc Dostie
Sep 24


Robot Arm Calibration Guide for Physical AI Teams
Learn robot arm calibration for research workflows, with guidance on joint zeroing, kinematics, TCP, camera alignment, validation, and data collection.
Marc Dostie
Sep 23
bottom of page