top of page
Latest News


Robot Training Data: Quality Standards for Physical AI
Learn how to evaluate robot training data for synchronized actions, metadata, task coverage, validation, bias, and readiness for physical AI policy training.
Marc Dostie
Sep 30
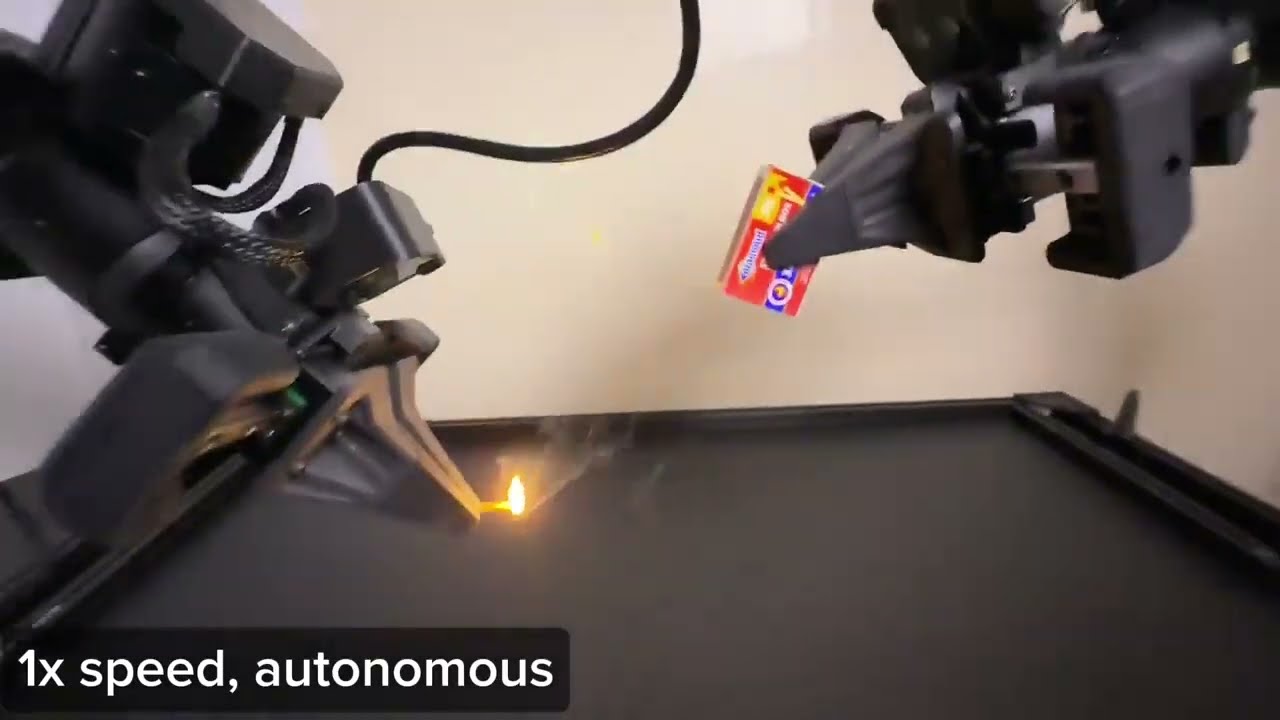
How Two Trossen Arms Learned to Strike a Match
Two Trossen arms struck a match completely on their own. The demo comes from NAC, research by Ahad Jawaid and Yu Xiang at UT Dallas heading to CoRL 2026, which borrows audio compression tricks to help robots learn precise, coordinated tasks.
Nupur Patra
Sep 29


Robotics Training Data: A Practical Capture Guide
Learn how to capture robotics training data with better task design, teleoperation, synchronized sensors, episode metadata, quality control, and evaluation.
Marc Dostie
Sep 29


Bimanual Manipulation: A Research Workflow Guide
Learn how bimanual manipulation teams coordinate arms, sensing, teleoperation, calibration, data capture, and evaluation for repeatable robot-learning research.
Marc Dostie
Sep 28


WidowX Robot Arm: Specs and Research Fit
Explore the WidowX robot arm's specifications, sensing, configurations, and software, then assess its fit for university, startup, and enterprise R&D workflows.
Marc Dostie
Sep 25
bottom of page